Robotics Technology

rover robot
MultiWheel All Terrain Vehicle
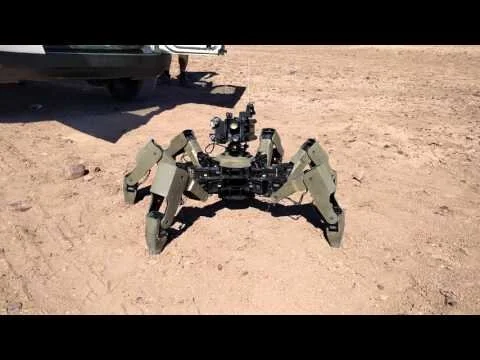
Hexapod Robot
Six Legged Crawler
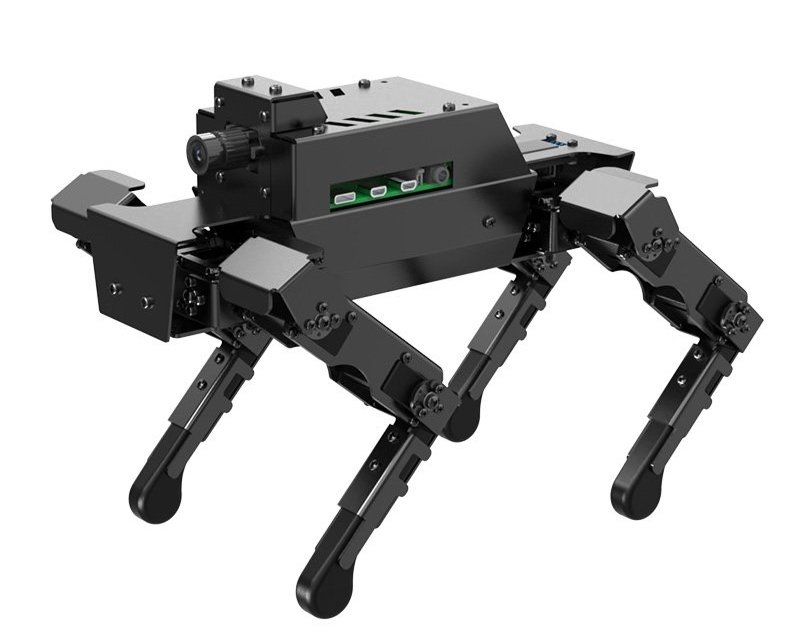
Quadruped Robot
Four Legged Crawler & Walker/Dog
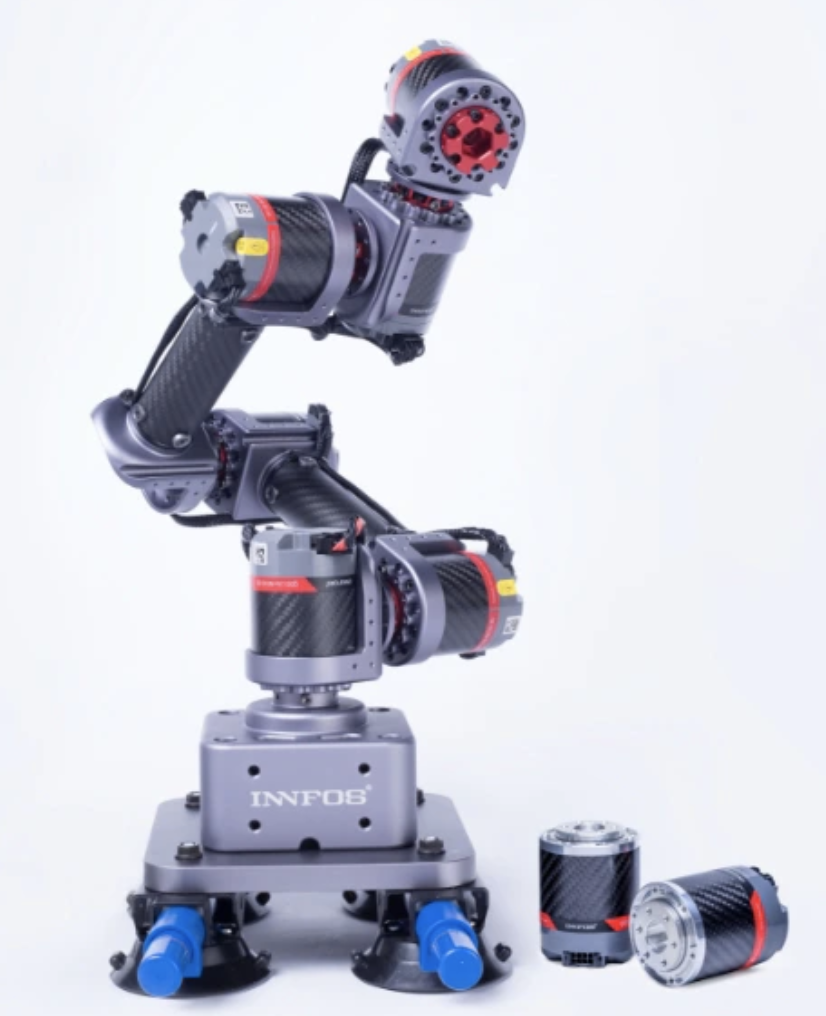
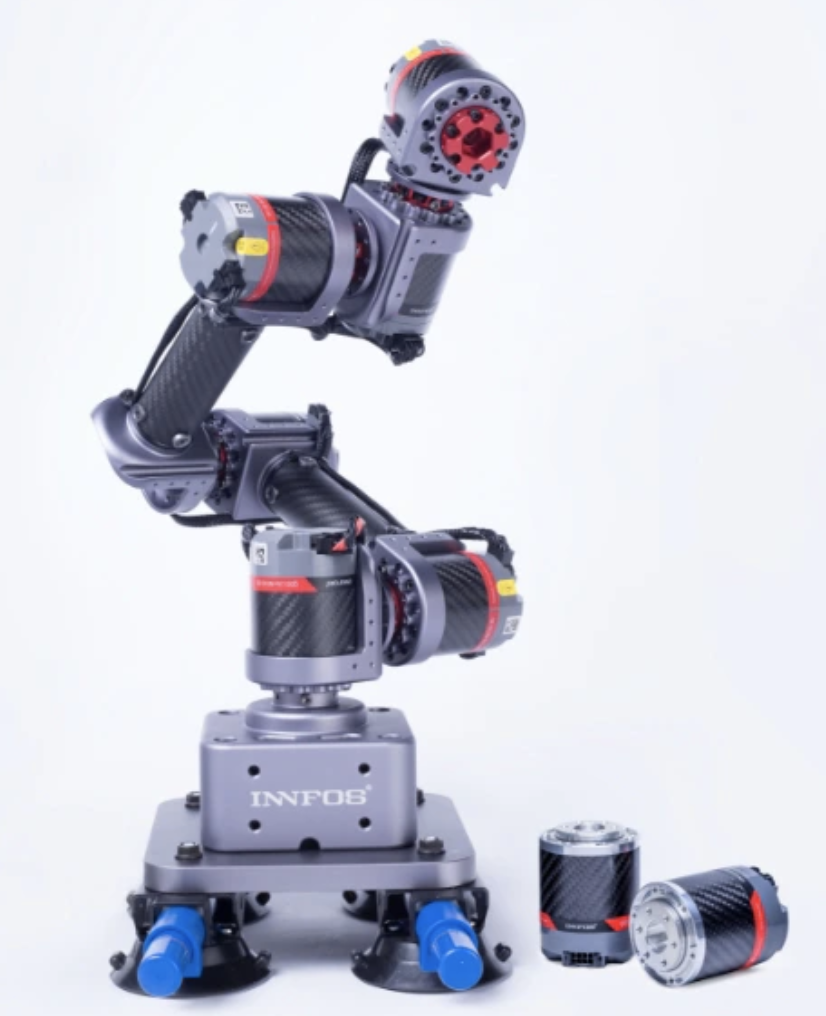
ROBOT Arm
Modular Robotic Arm

The blog post on TechnologyX2 details a project for remotely controlling a 4DOF (Four Degrees of Freedom) Arduino robot arm using hand gestures. The control is achieved through an Inertial Measurement Unit (IMU) sensor which captures the hand's motion in x, y, z axes and transmits the movements to the robot arm over Bluetooth. Key components include a Lafvin Arduino Nano clone, HiLetgo HC-05 Bluetooth Master Module, HC-06 Bluetooth Slave Module, and a GY-521 MPU6050 3-Axis Accelerometer Gyro Module. The project emphasizes the importance of problem-solving in engineering, and the author shares insights and troubleshooting tips based on their experience in configuring and testing these components. For more details, you can read the full article [here](https://www.technologyx2.com/blog_hightech/2021/5/23/project-remotely-control-arduino-robot-arm-using-imu-sensor-over-bluetooth).

Bipedal humanoid
Two Legged Human Robot
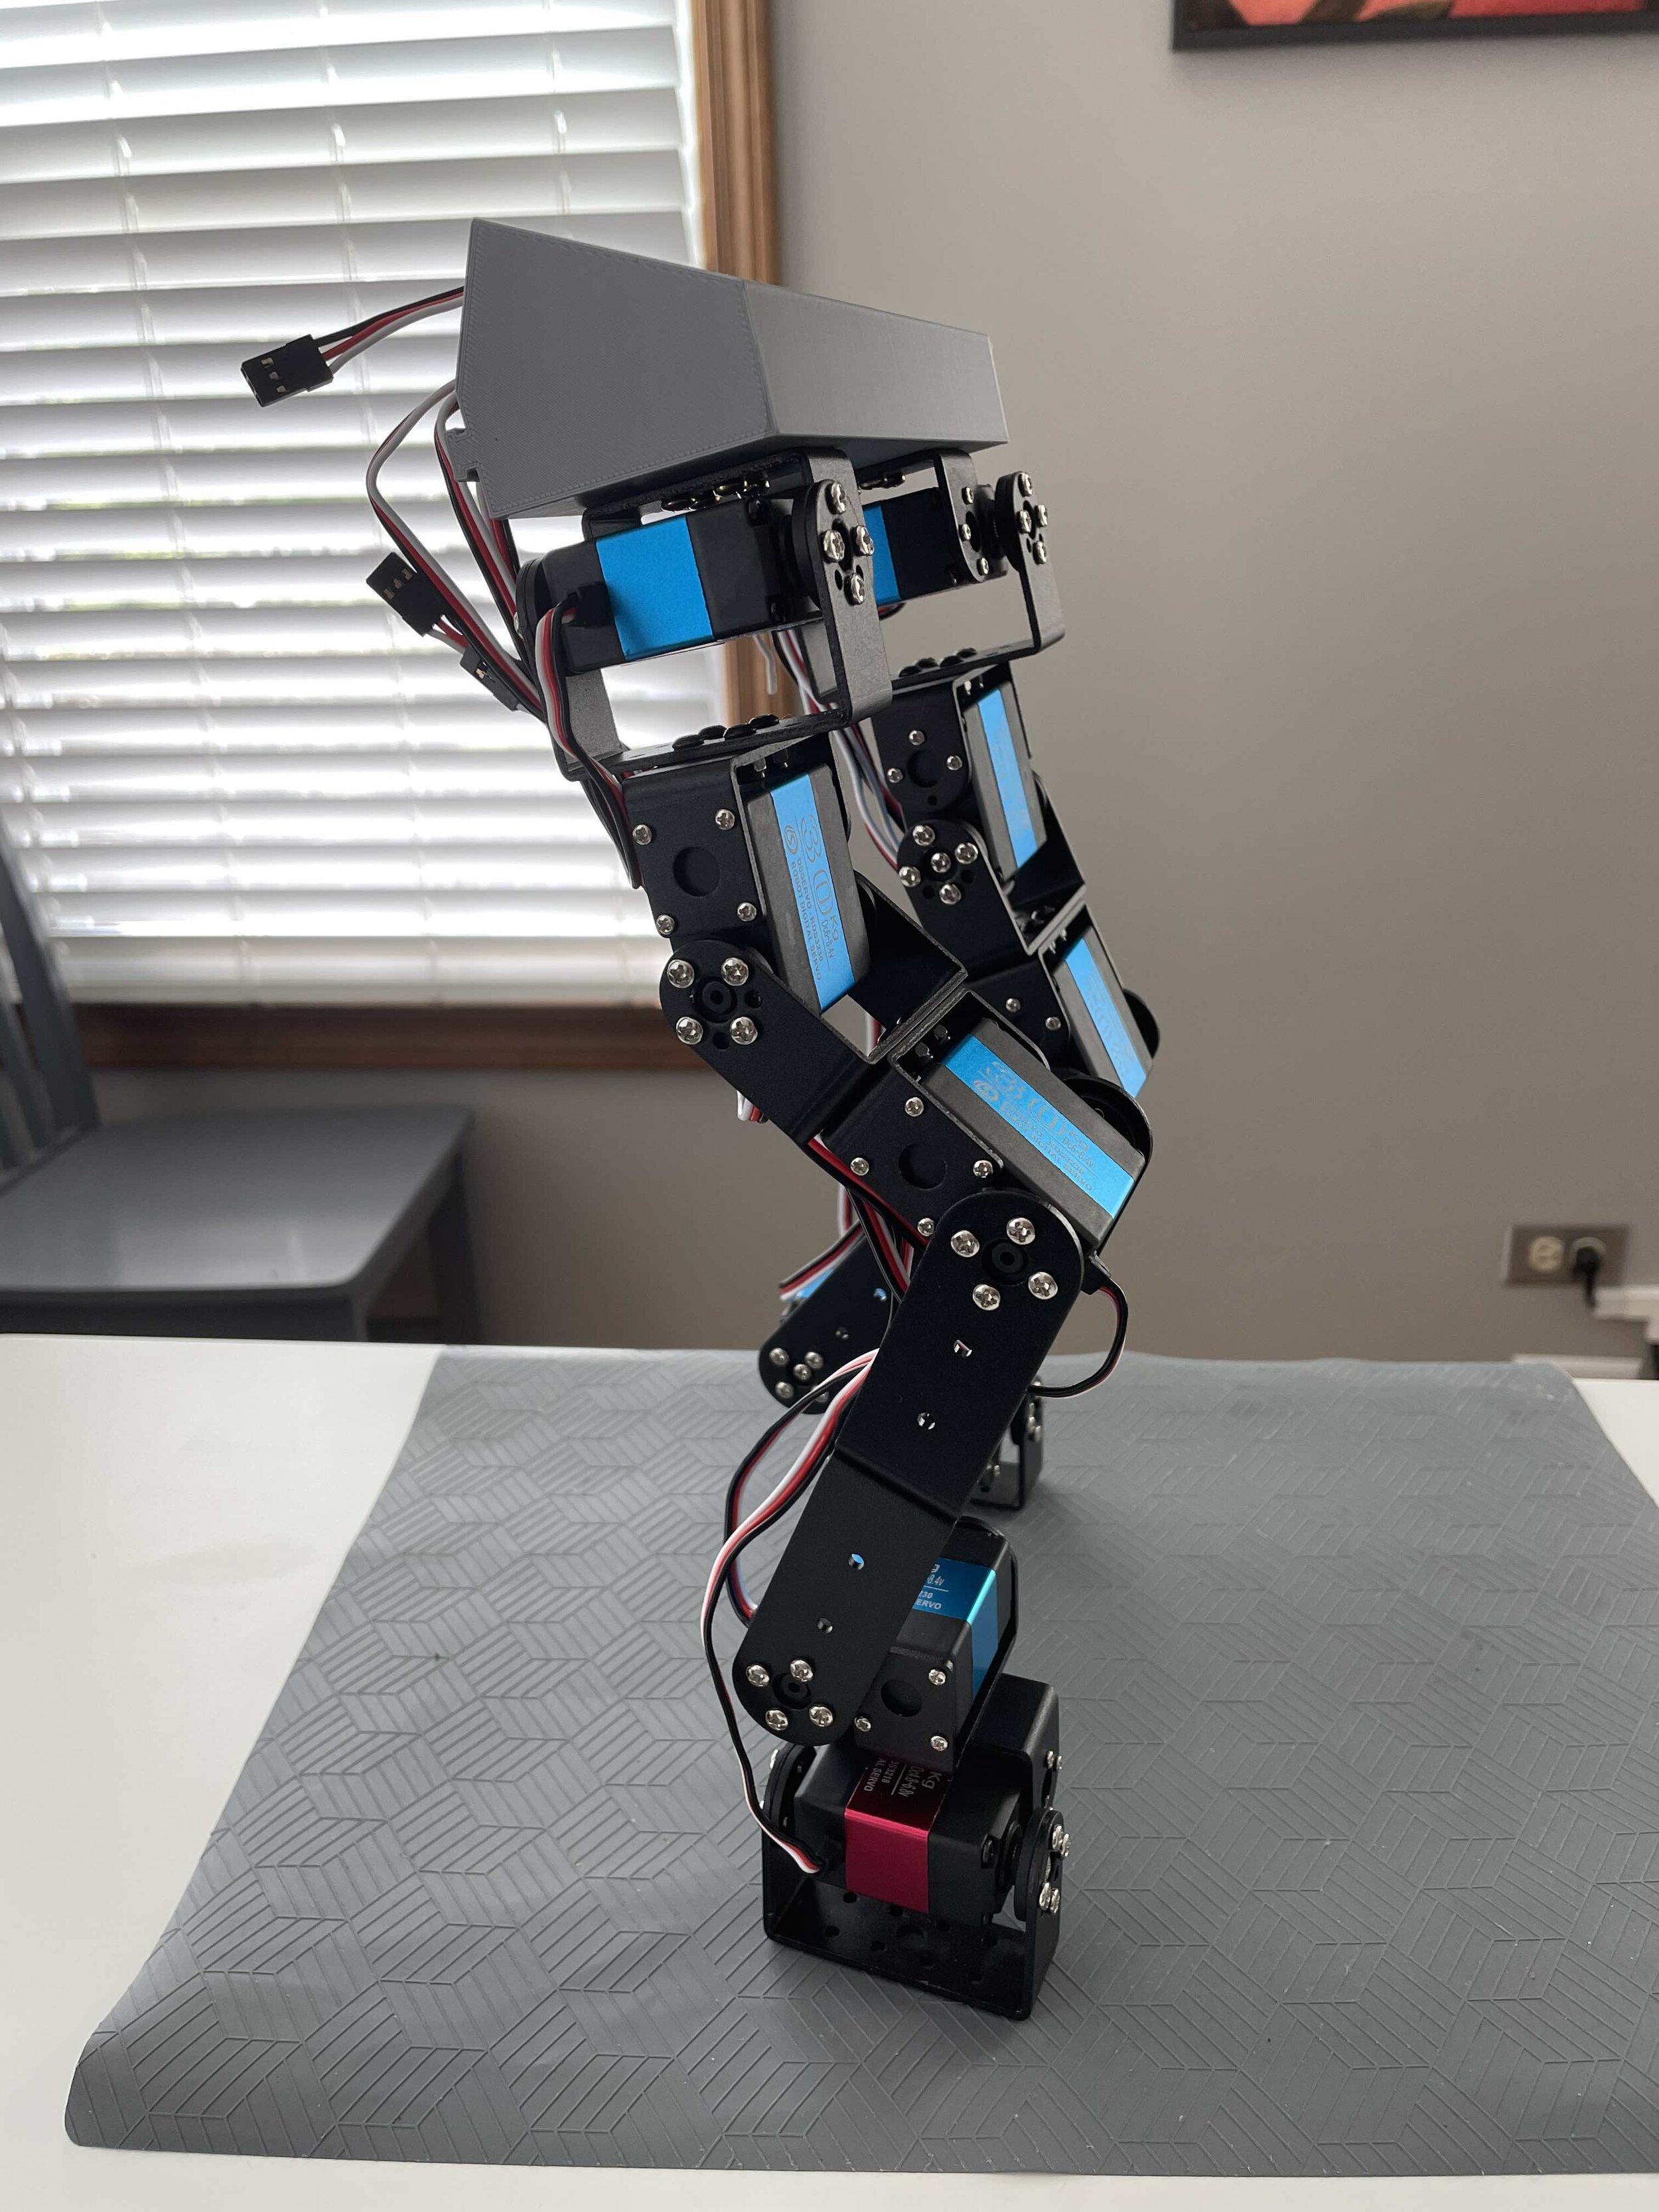
The blog post on TechnologyX2 discusses the author's decade-long experience with autonomous drone technology and biped (two-legged) humanoid robots. The focus is on a recent project involving a simple bipedal robot built with hobby servos and a 3-axis gyro sensor. This sensor helps the robot maintain balance by detecting angular changes and responding with compensatory movements. Inspired by advancements in robot soccer players and the Thousand Brains theory by Jeff Hawkins, the author aims to explore new theories and applications in robotics, starting with the basic construction of the robot's lower half using high torque servos. The project is seen as a long-term endeavor, continuing the author's exploration of AI and robotics. For more details, you can view the full post [here](https://www.technologyx2.com/blog_hightech/2021/6/6/project-bipedal-self-balancing-humanoid-robot-bare-metal-robot-using-hobby-servos).
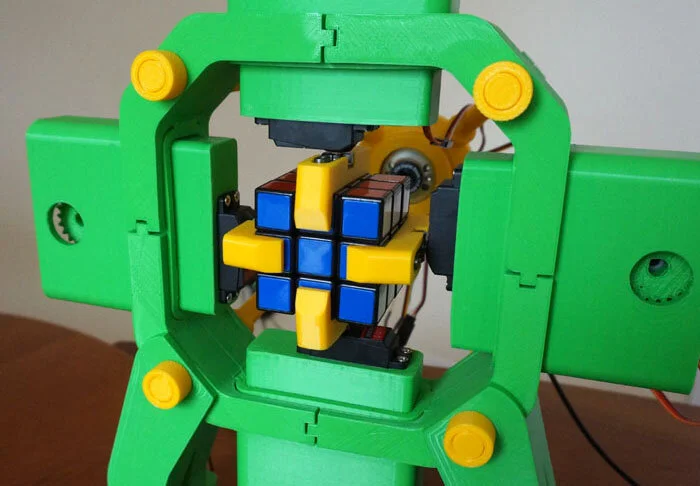
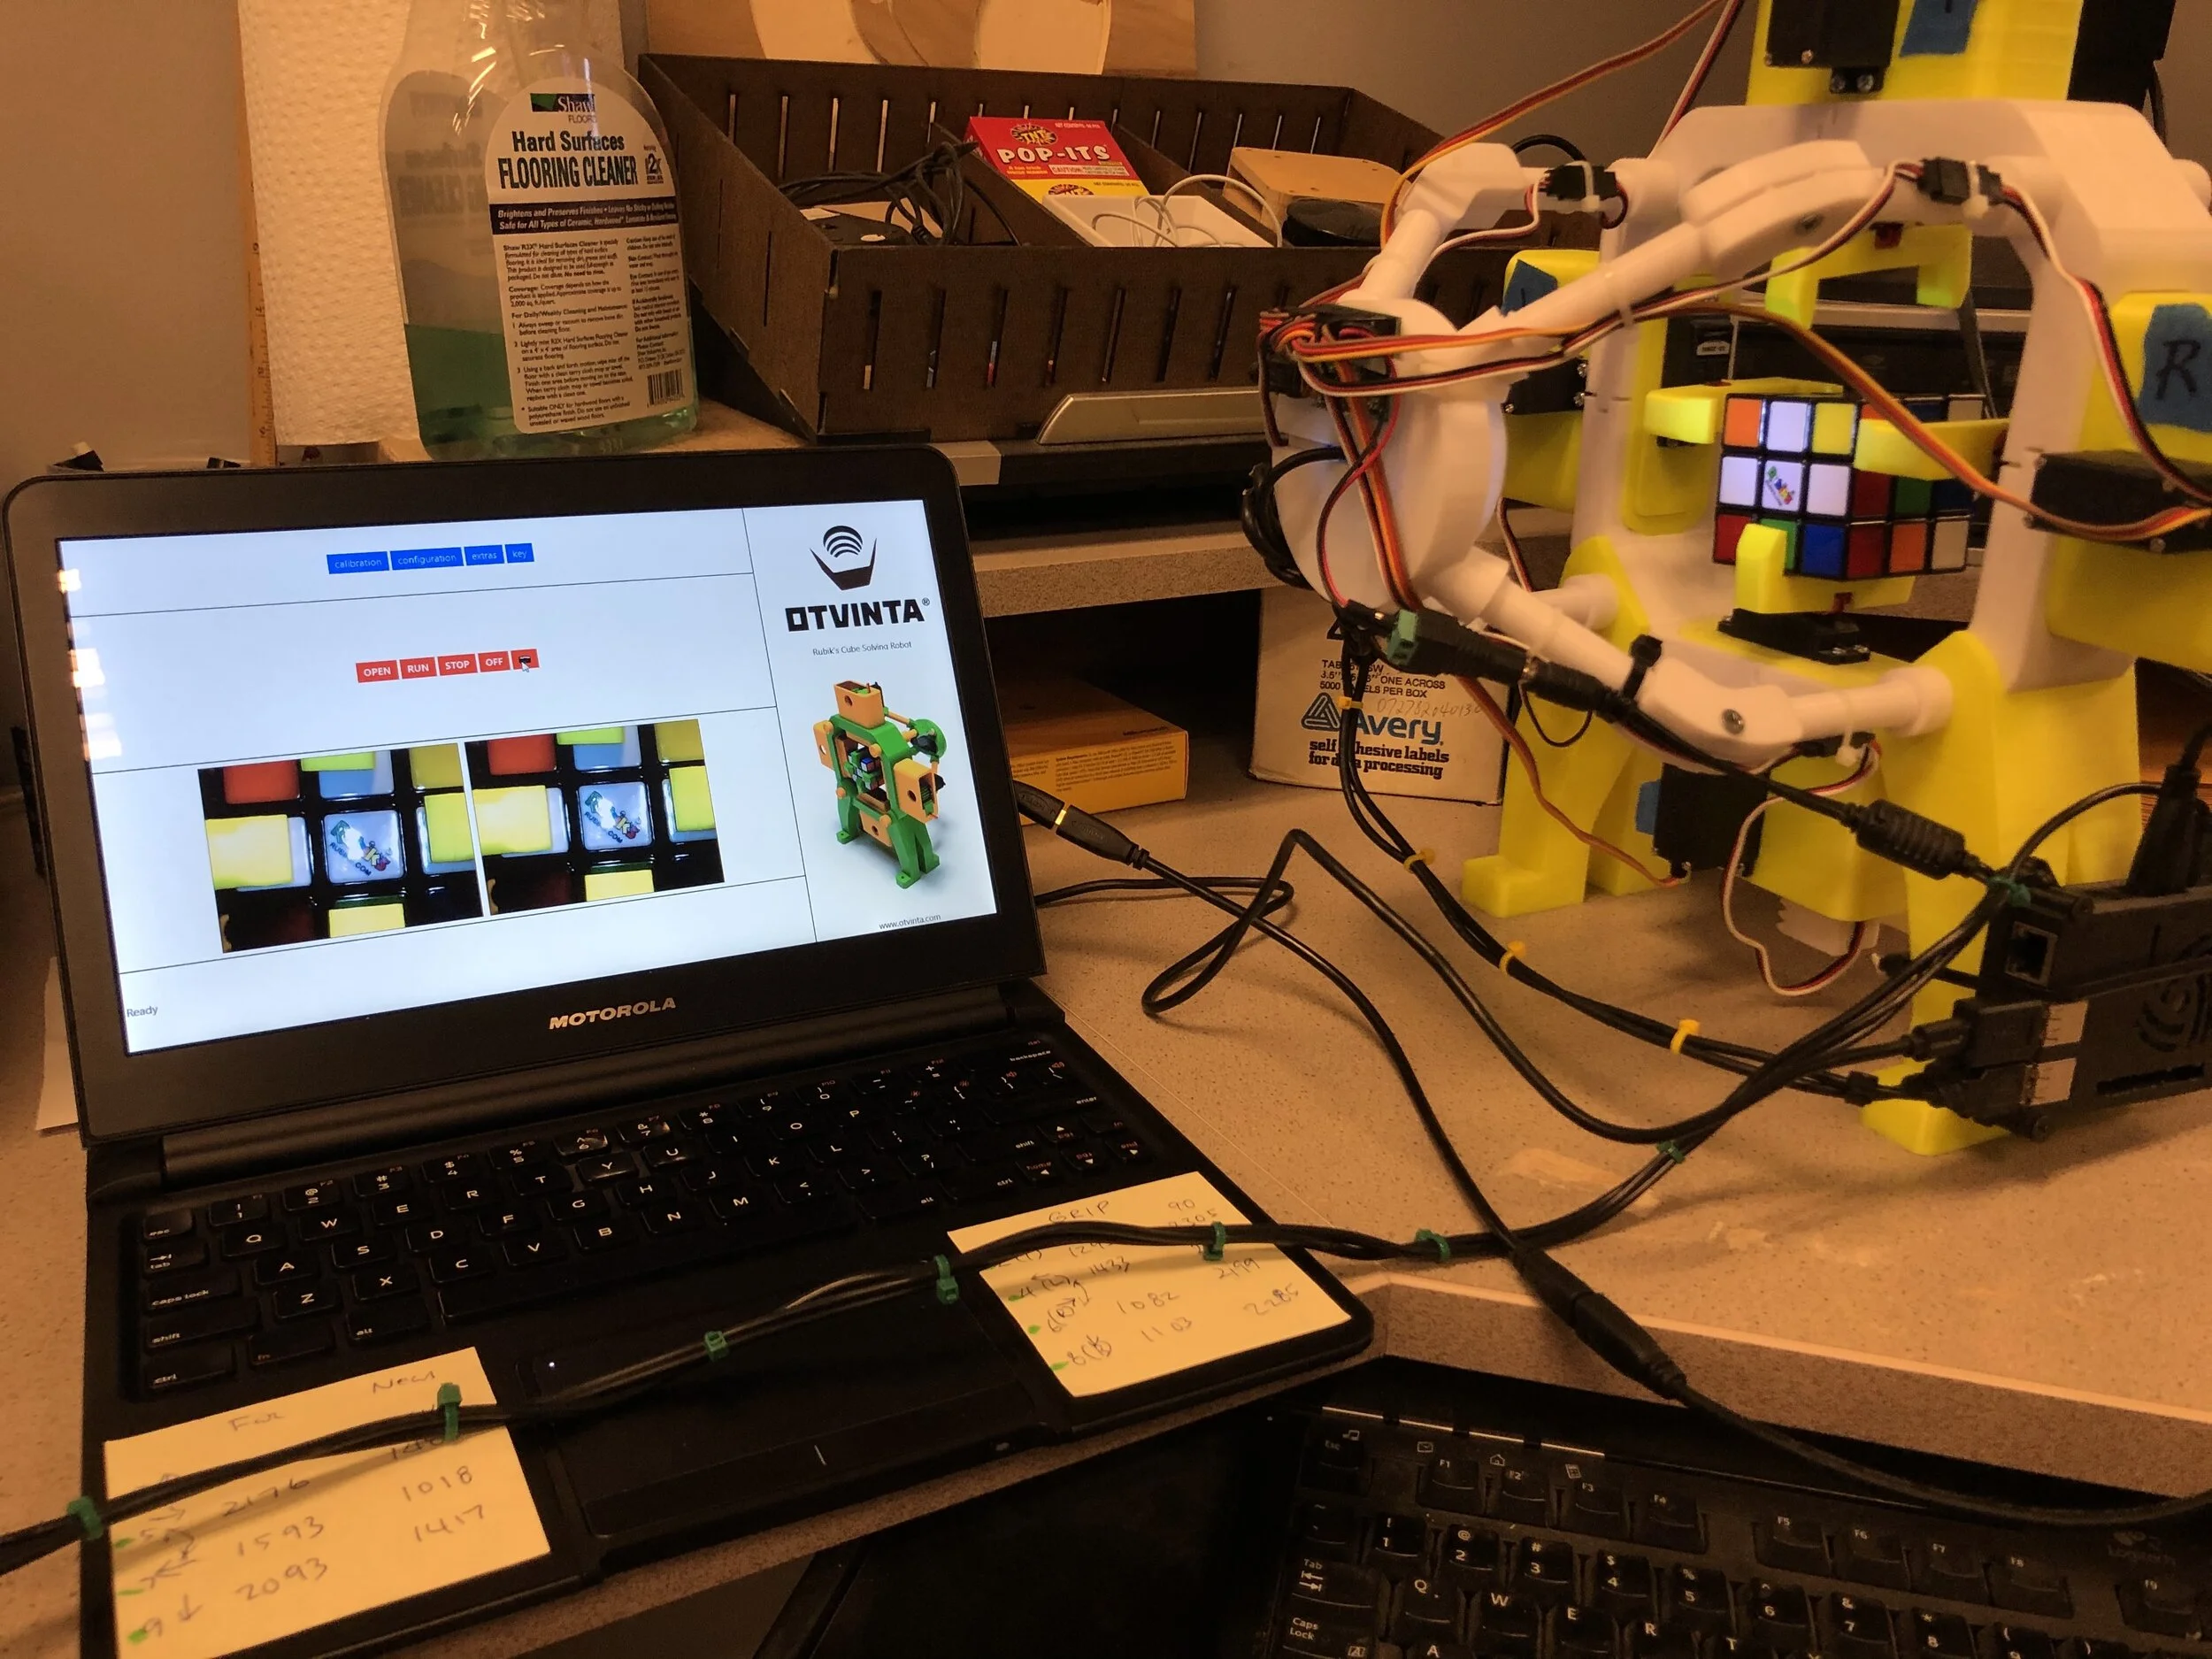
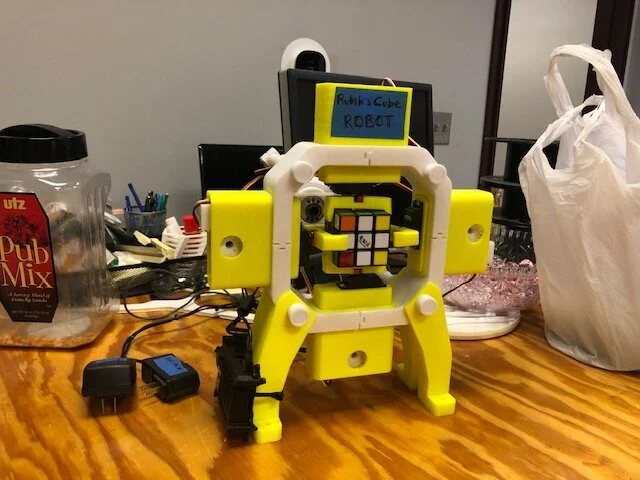
Rubik’s cube solving robot
3D Printed Robot - Otvinta
Robot Operating Systems
ROS Platform
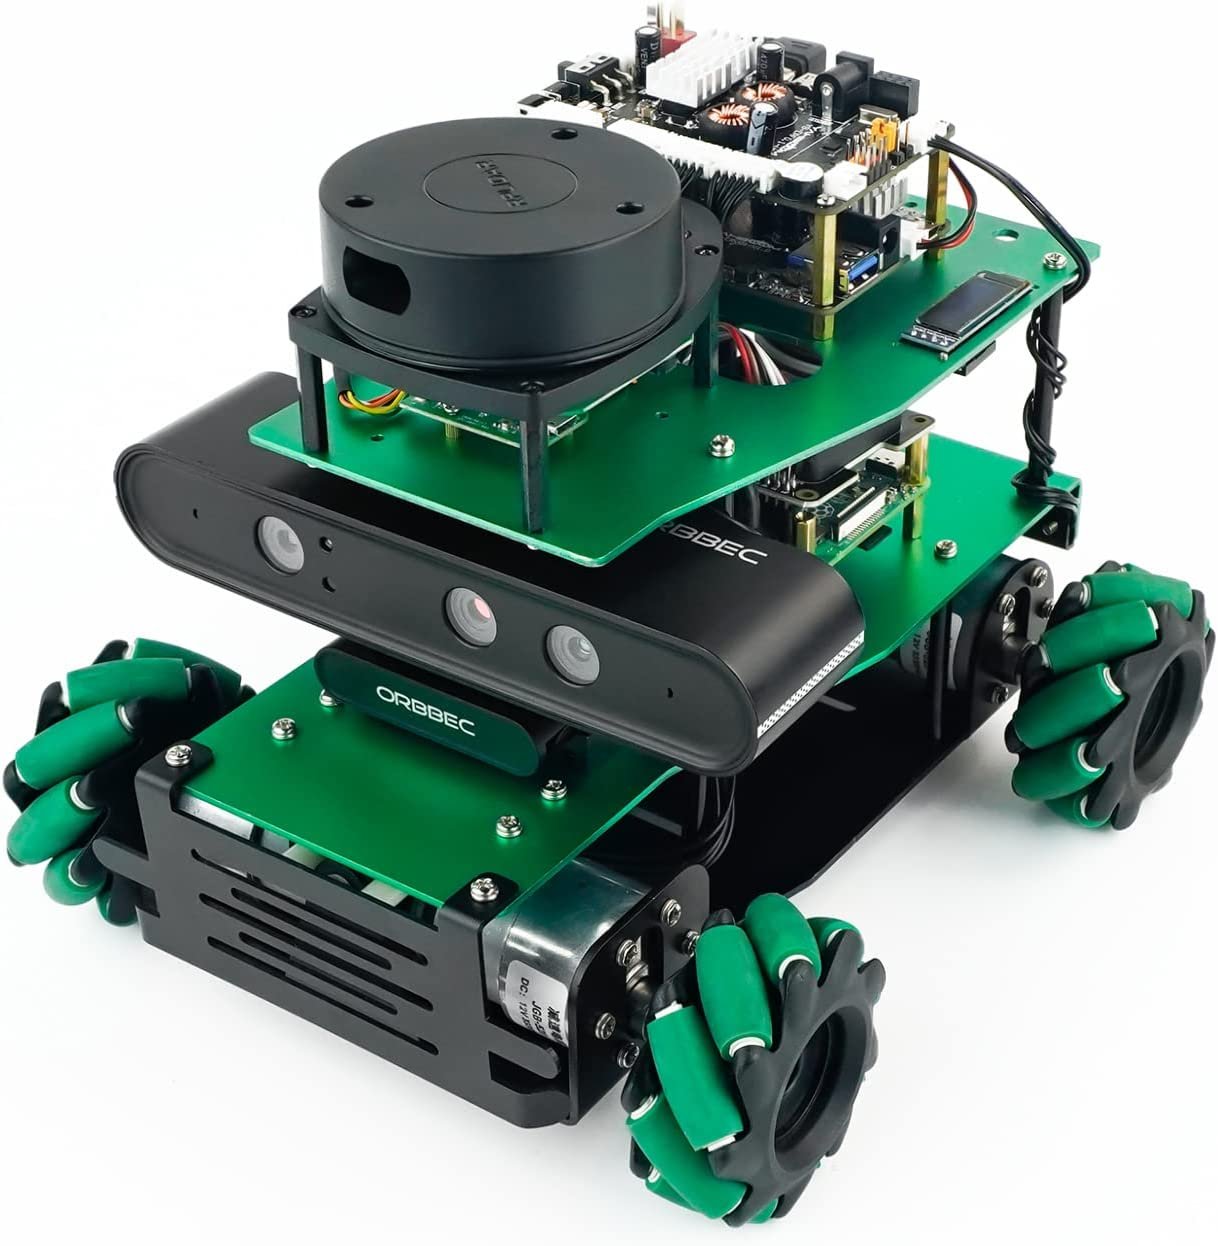

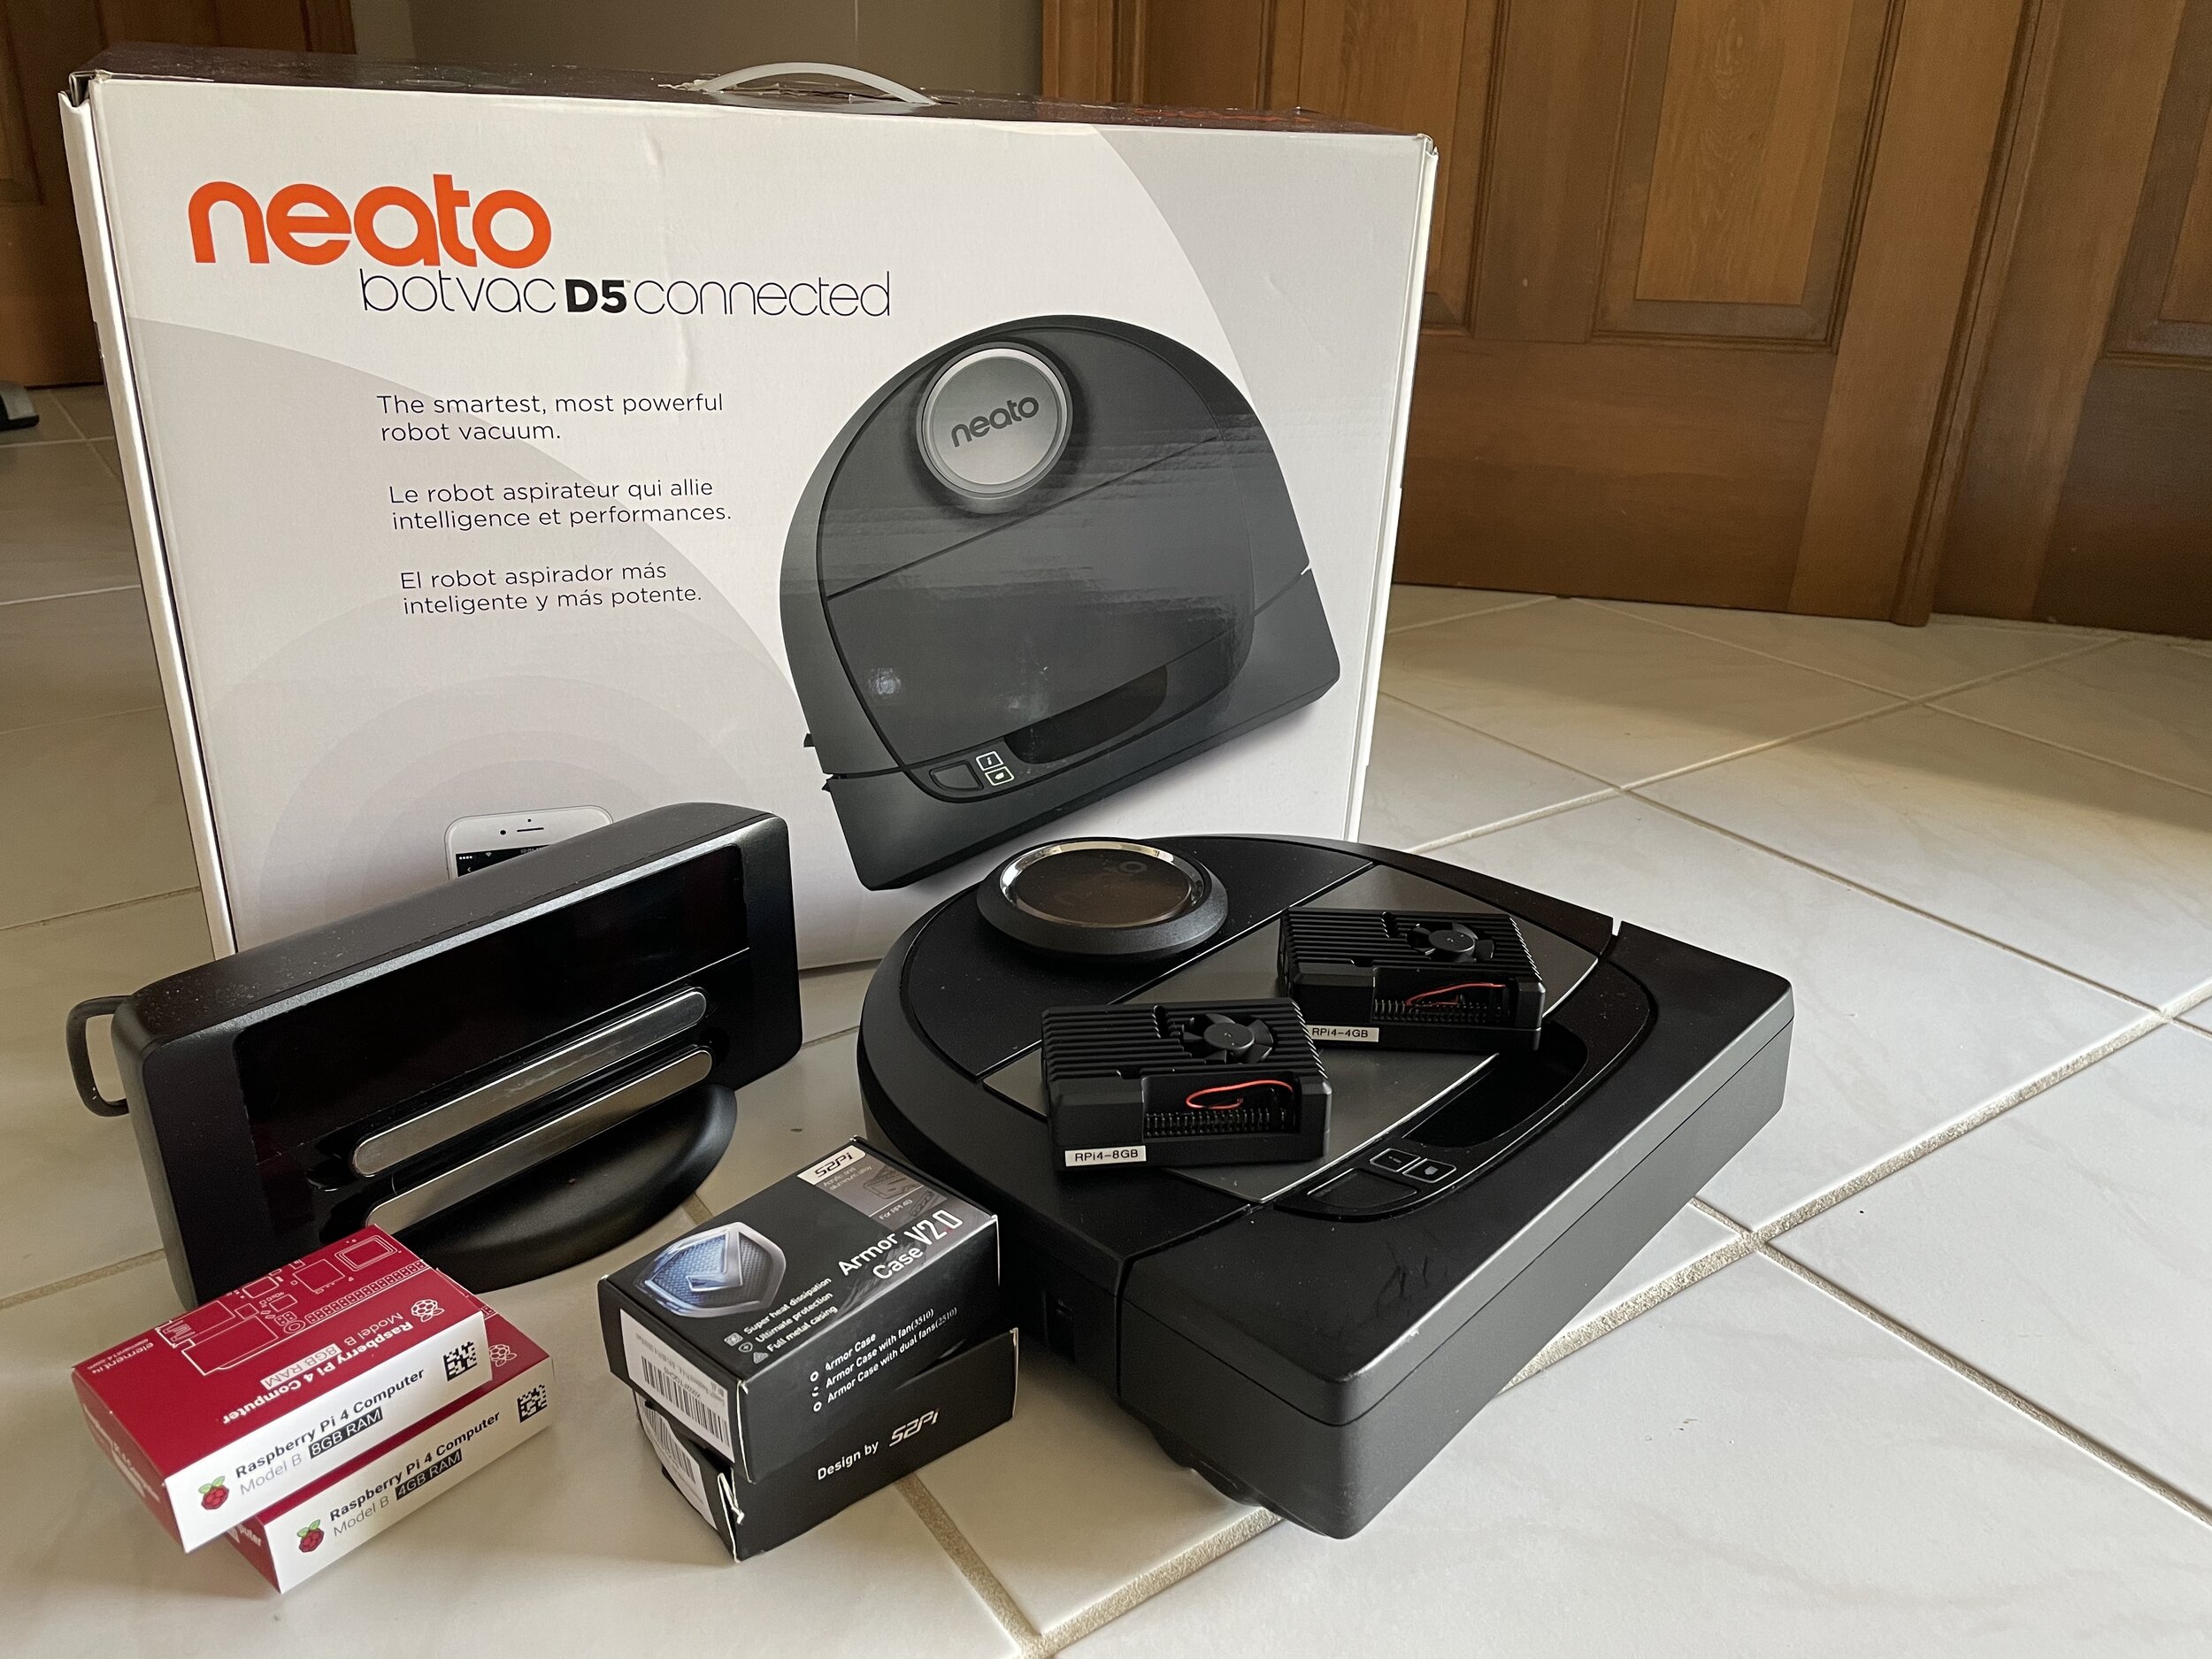
The blog post on Technology x2 details a project involving ROS2 (Robot Operating System version 2) and its application in a robotics project using the Neato BotVac D5 Connected Robot and a Raspberry Pi4 with 8GB RAM. The author discusses the advantages of ROS2, including improved module communication, Python3 support, and enhanced security. The project aims to enhance human-robot interaction with a focus on mobility, safety, and diverse communication methods. It involves customizing the Neato BotVac to house the Raspberry Pi4 and Arduino Mega, and setting up Linux Ubuntu with ROS2 on the Raspberry Pi4. The post also covers challenges and learning experiences encountered during the installation of ROS2 on the Raspberry Pi. For a detailed read, you can view the blog post [here](https://www.technologyx2.com/blog_hightech/2021/6/6/project-ros2-using-neato-botvac-d5-connected-robot-amp-raspberry-pi4-8bg).
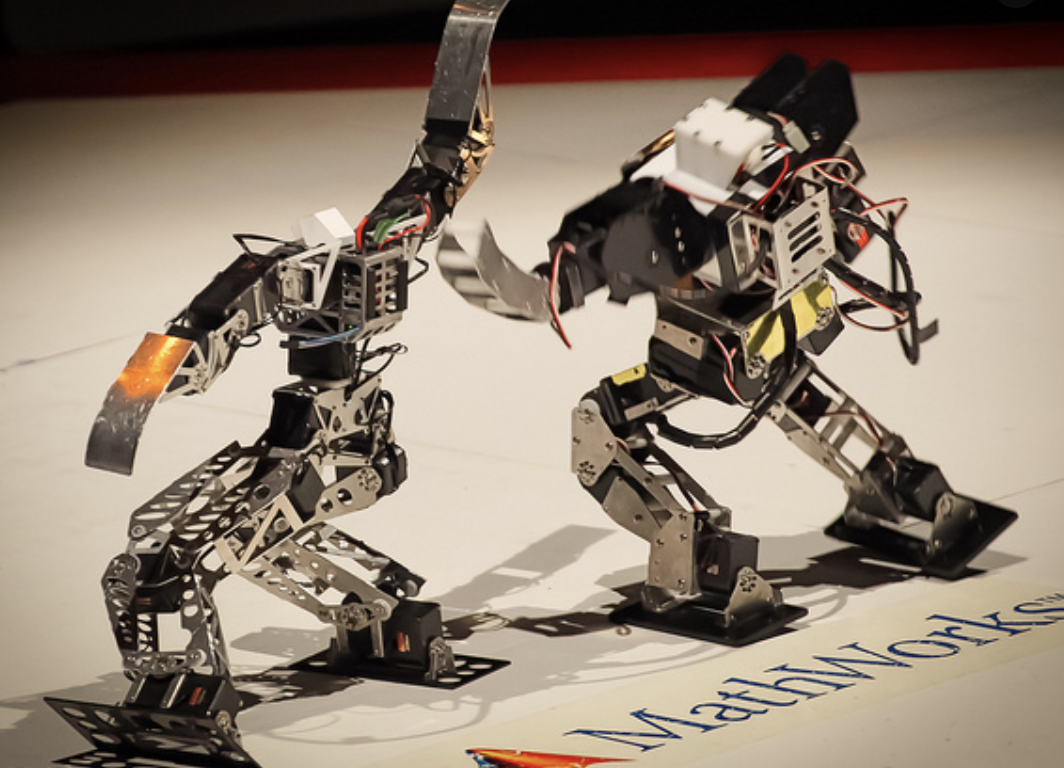
Robot Competitions
Robot Games & Competitions
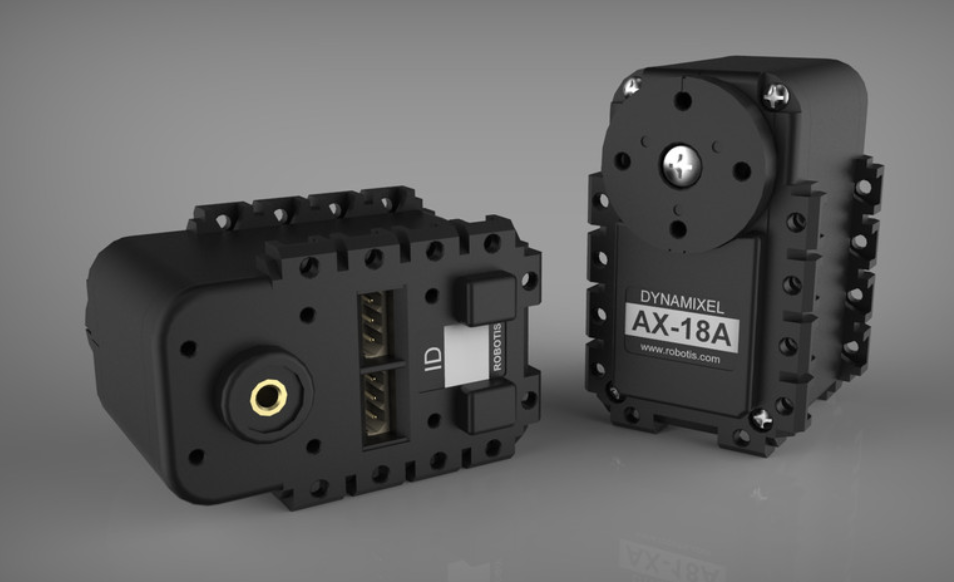
Robot Components
Robot Parts and Components